Autonomous Robot Navigation
Building a vision-guided robot that navigates dynamic environments with real-time path planning and obstacle avoidance.
- ROLE / AUTHORSHIP
- Lead software engineer
- PROJECT STATUS
- Active development
- RECORD YEAR
- 2026 · Sample record
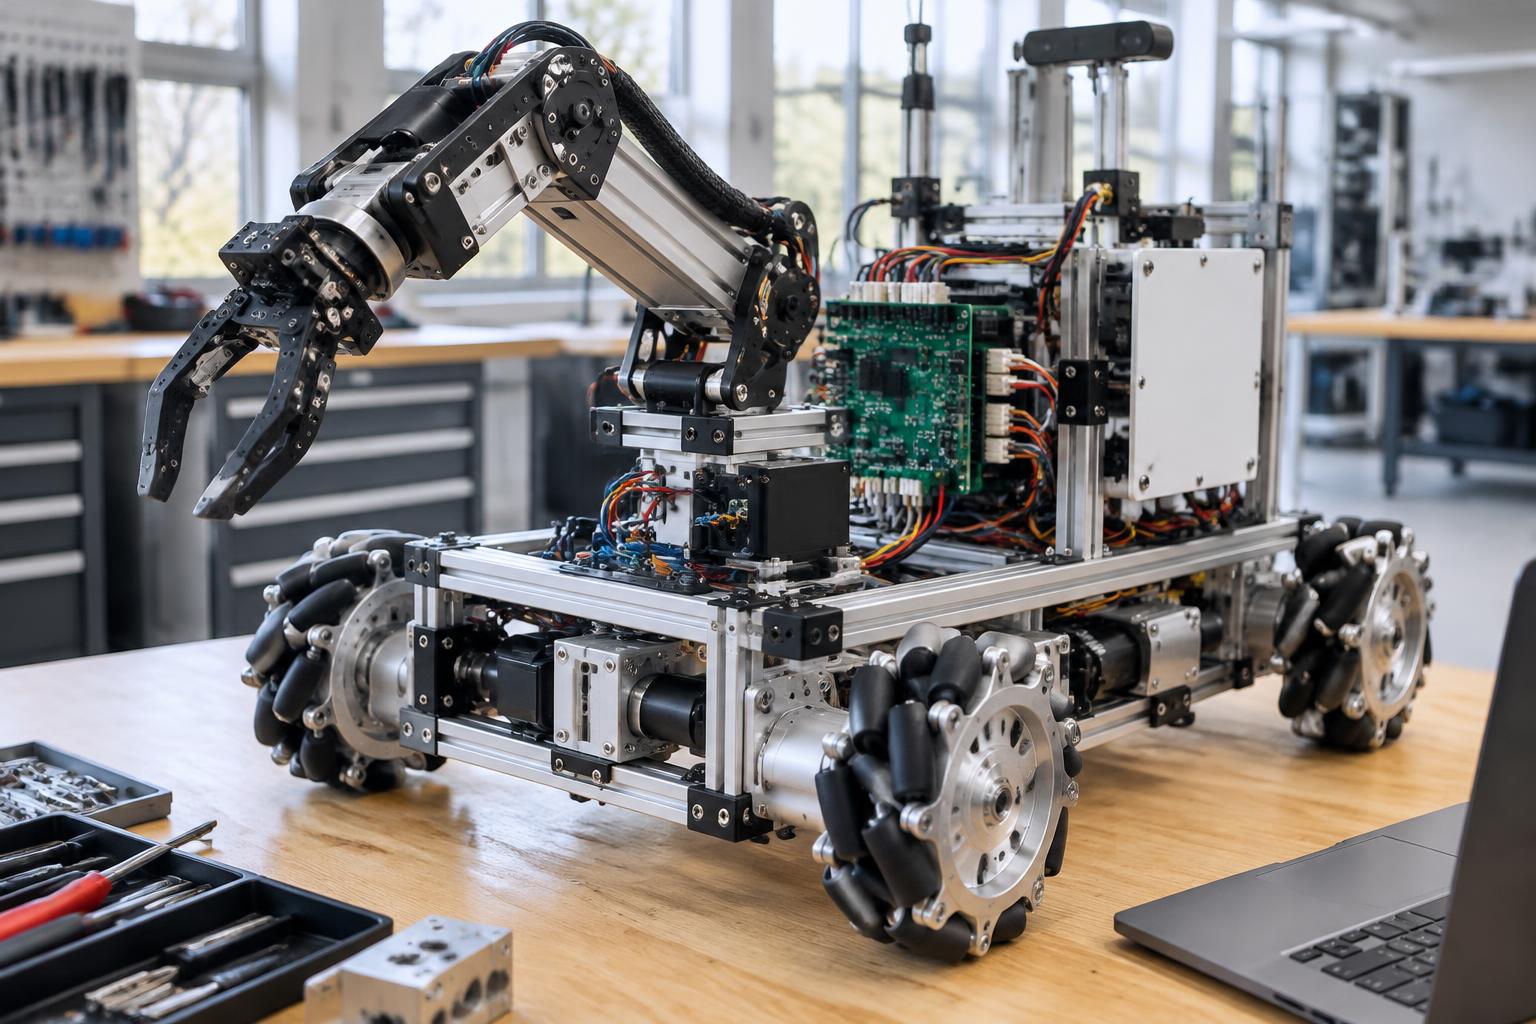
Problem & objective
Building a vision-guided robot that navigates dynamic environments with real-time path planning and obstacle avoidance.
Methods & evaluation
Sample method: calibrate stereo perception, build an occupancy grid, integrate A* planning with PID control, and evaluate success rate and latency over controlled navigation trials.
System architecture
- 01
Stereo camera
- 02
visual localization
- 03
occupancy grid
- 04
A* path planner
- 05
PID motor controller. A ROS 2 message bus connects perception and control.
Results & findings
Sample benchmark: 94% successful navigation over 50 controlled trials; 120 ms perception latency.
Limitations & pending evidence
Physical testing protocol, environmental diversity, collision statistics, and raw trial logs are pending. The illustrative benchmark is not independently verified.